Reference approach

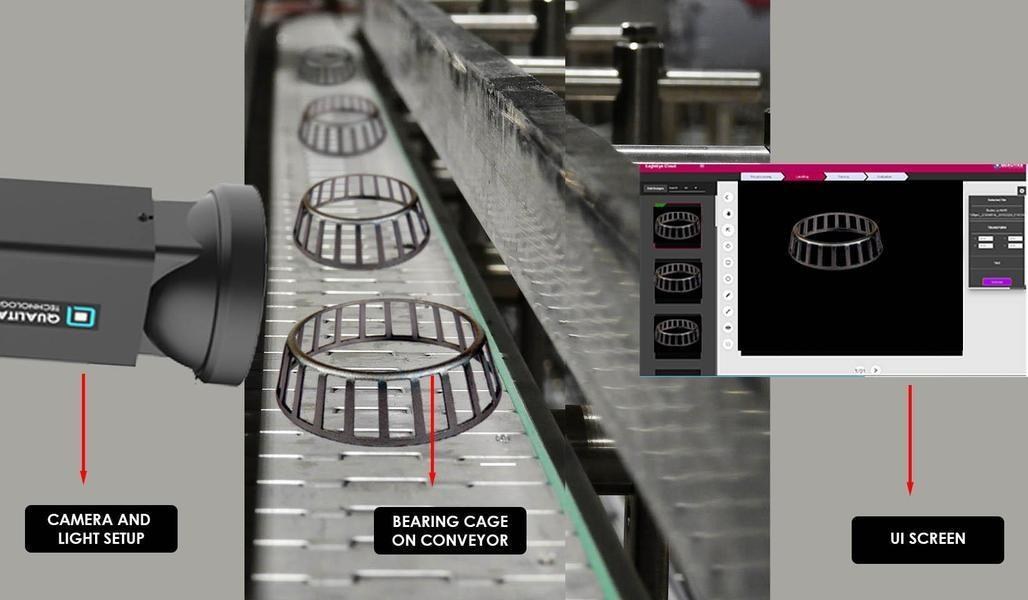
Locate accessible cylinders, calibrate the camera view to robot coordinates and send a permitted pick position to the robot controller. Verify handling state after the move.
What a pilot should establish
- Test cylinder offsets, orientation changes, partial visibility and gripper approach clearance.
- Agree the pass, fail and uncertain outcomes before testing. Record incorrect accepts and incorrect rejects separately using an independent sample set.
Camera calibration and mechanical repeatability affect placement. Robot safety and collision avoidance remain separate engineering responsibilities.
Outputs and line integration
Define the result required by the next process step, the time available to return it and the action for an uncertain result. Where records are needed, keep the image and decision tied to the inspected item or handling event.
Technical reference
Share cylinder geometry, gripper details and robot interface. We can define the imaging approach, integration points and a sample-based validation plan.
Evaluate this application